Oct. 2025·Sole Designer & Builder·Treehouse Showcase
Pick-and-place Robot Arm
4-DOF SCARA-style arm with geared, belt, and lead-screw drives. SolidWorks, 3D printed, controlled in C++.
- SolidWorks
- C++
- Stepper motors
- 3D printing
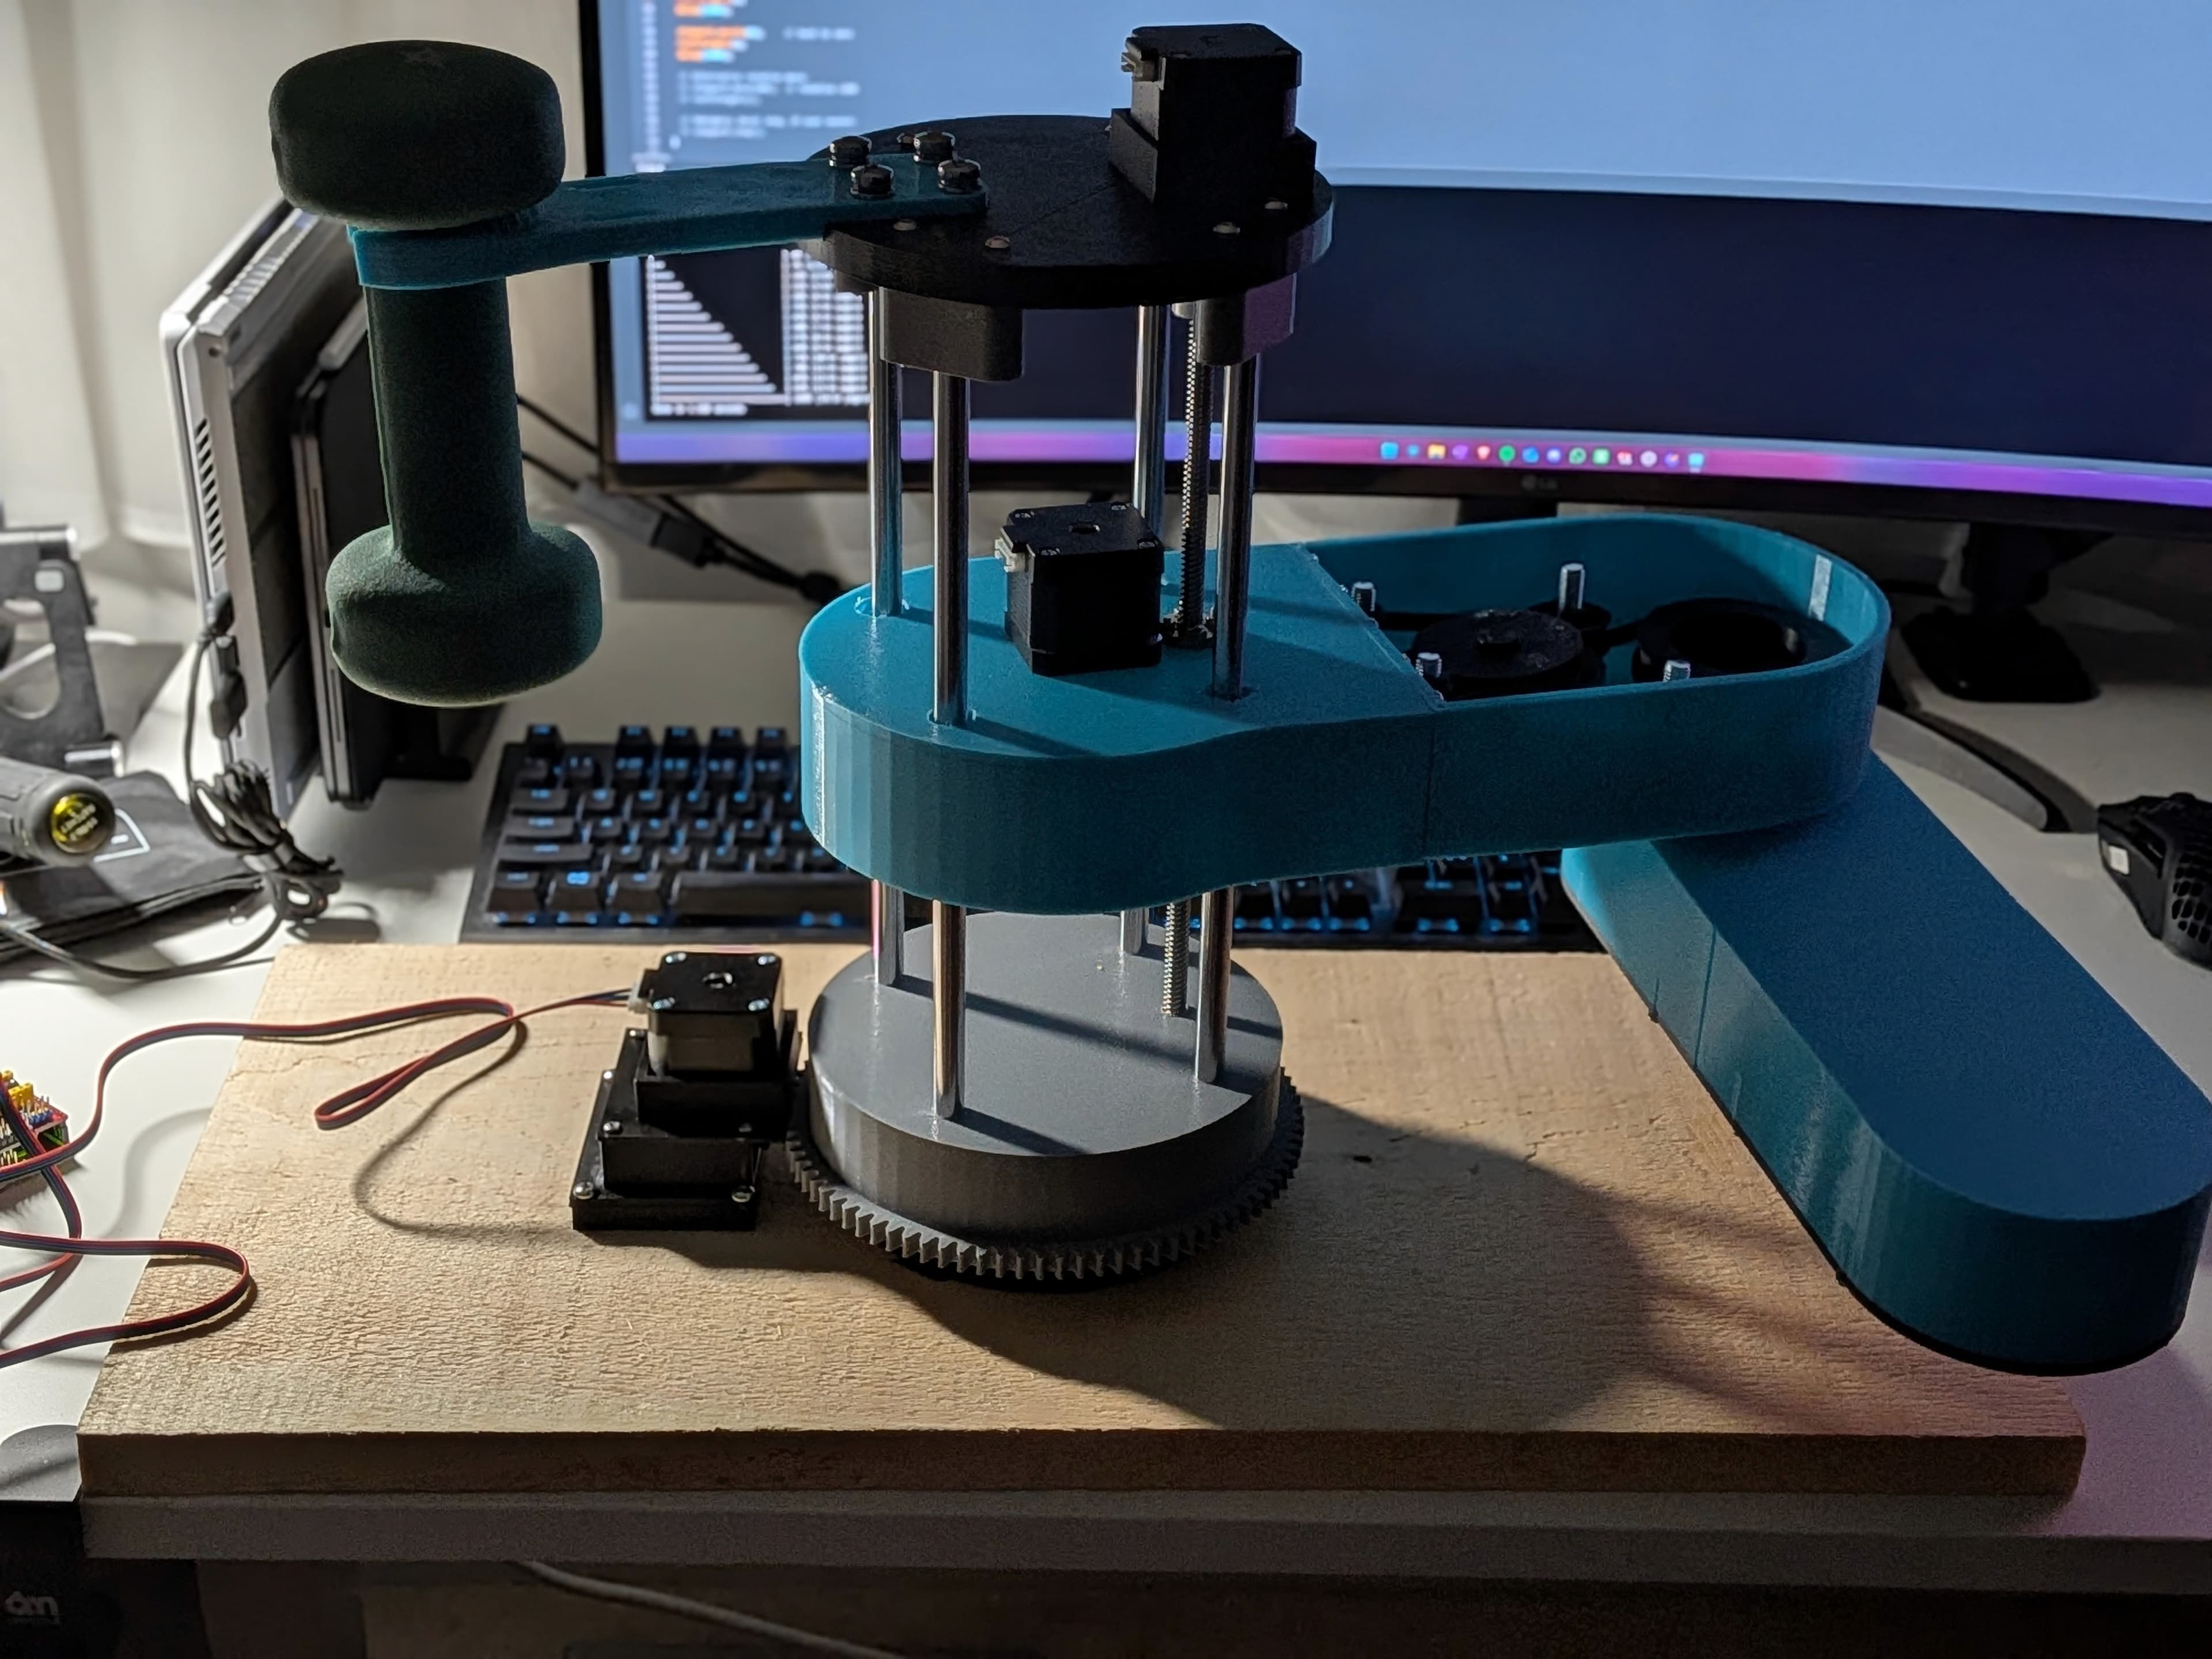
I designed, printed, wired, and programmed this SCARA-style pick-and-place arm, then presented it at Treehouse / Socratica on Oct 8, 2025 to 100+ people.
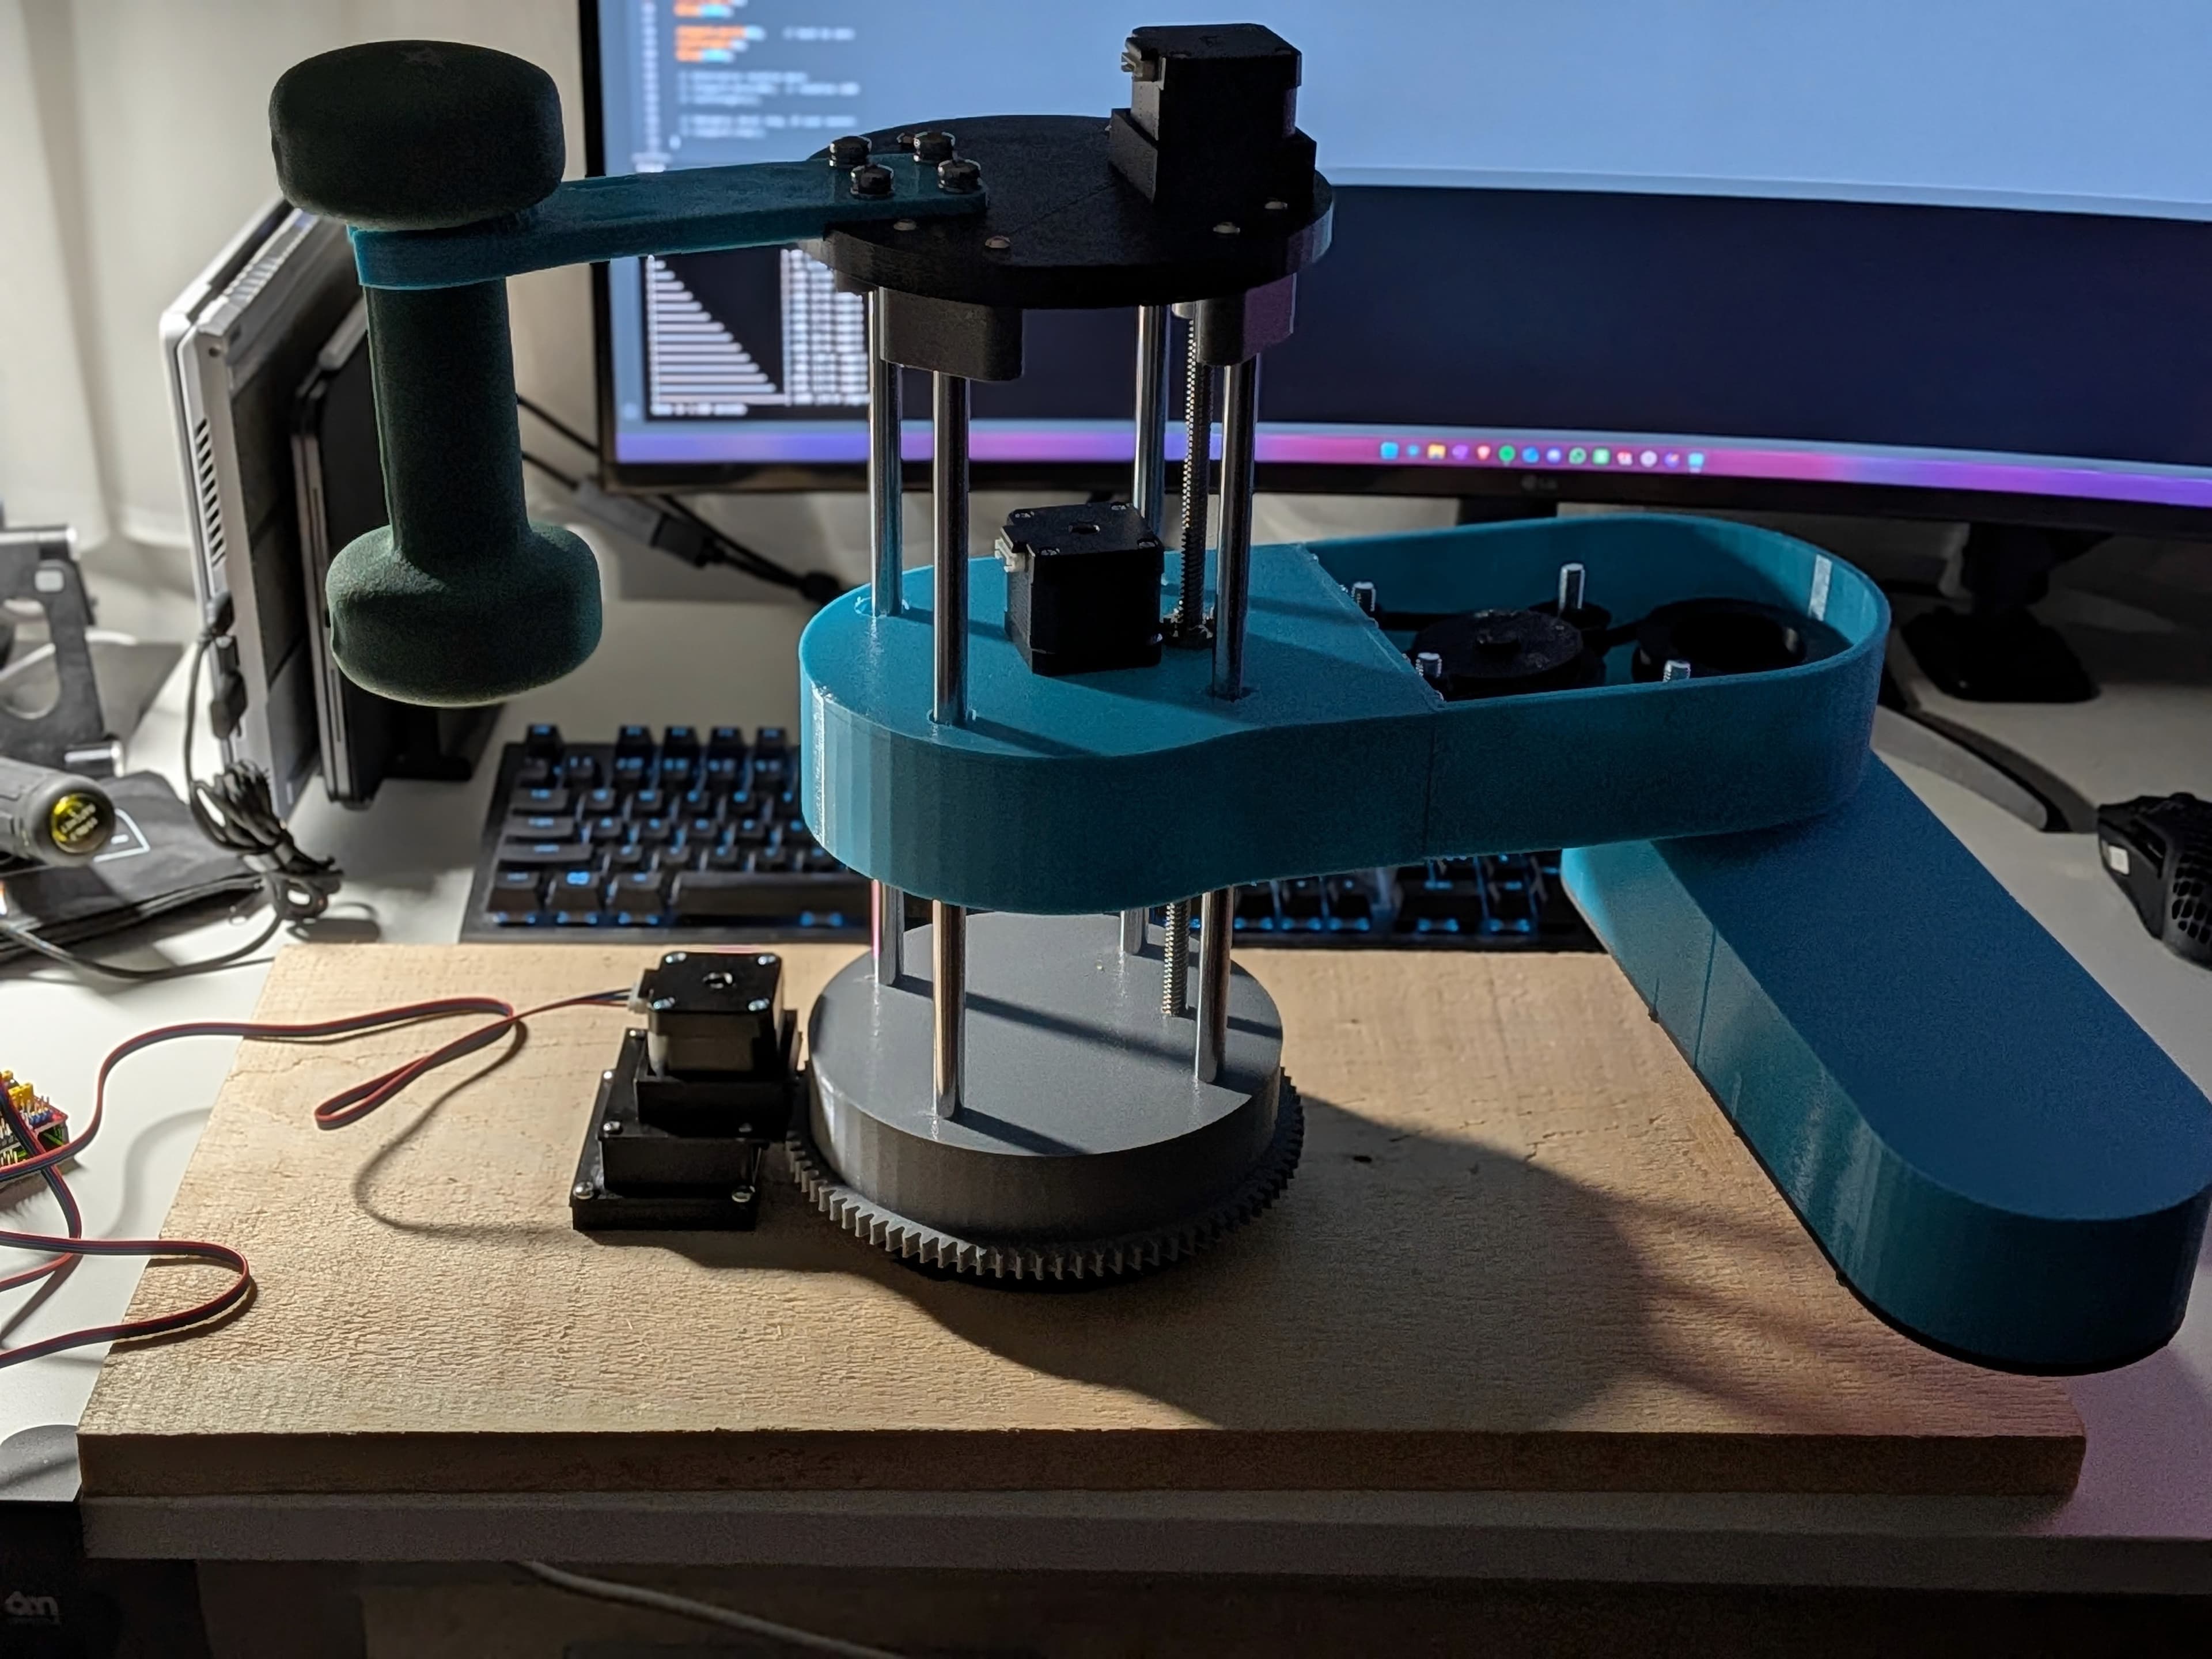
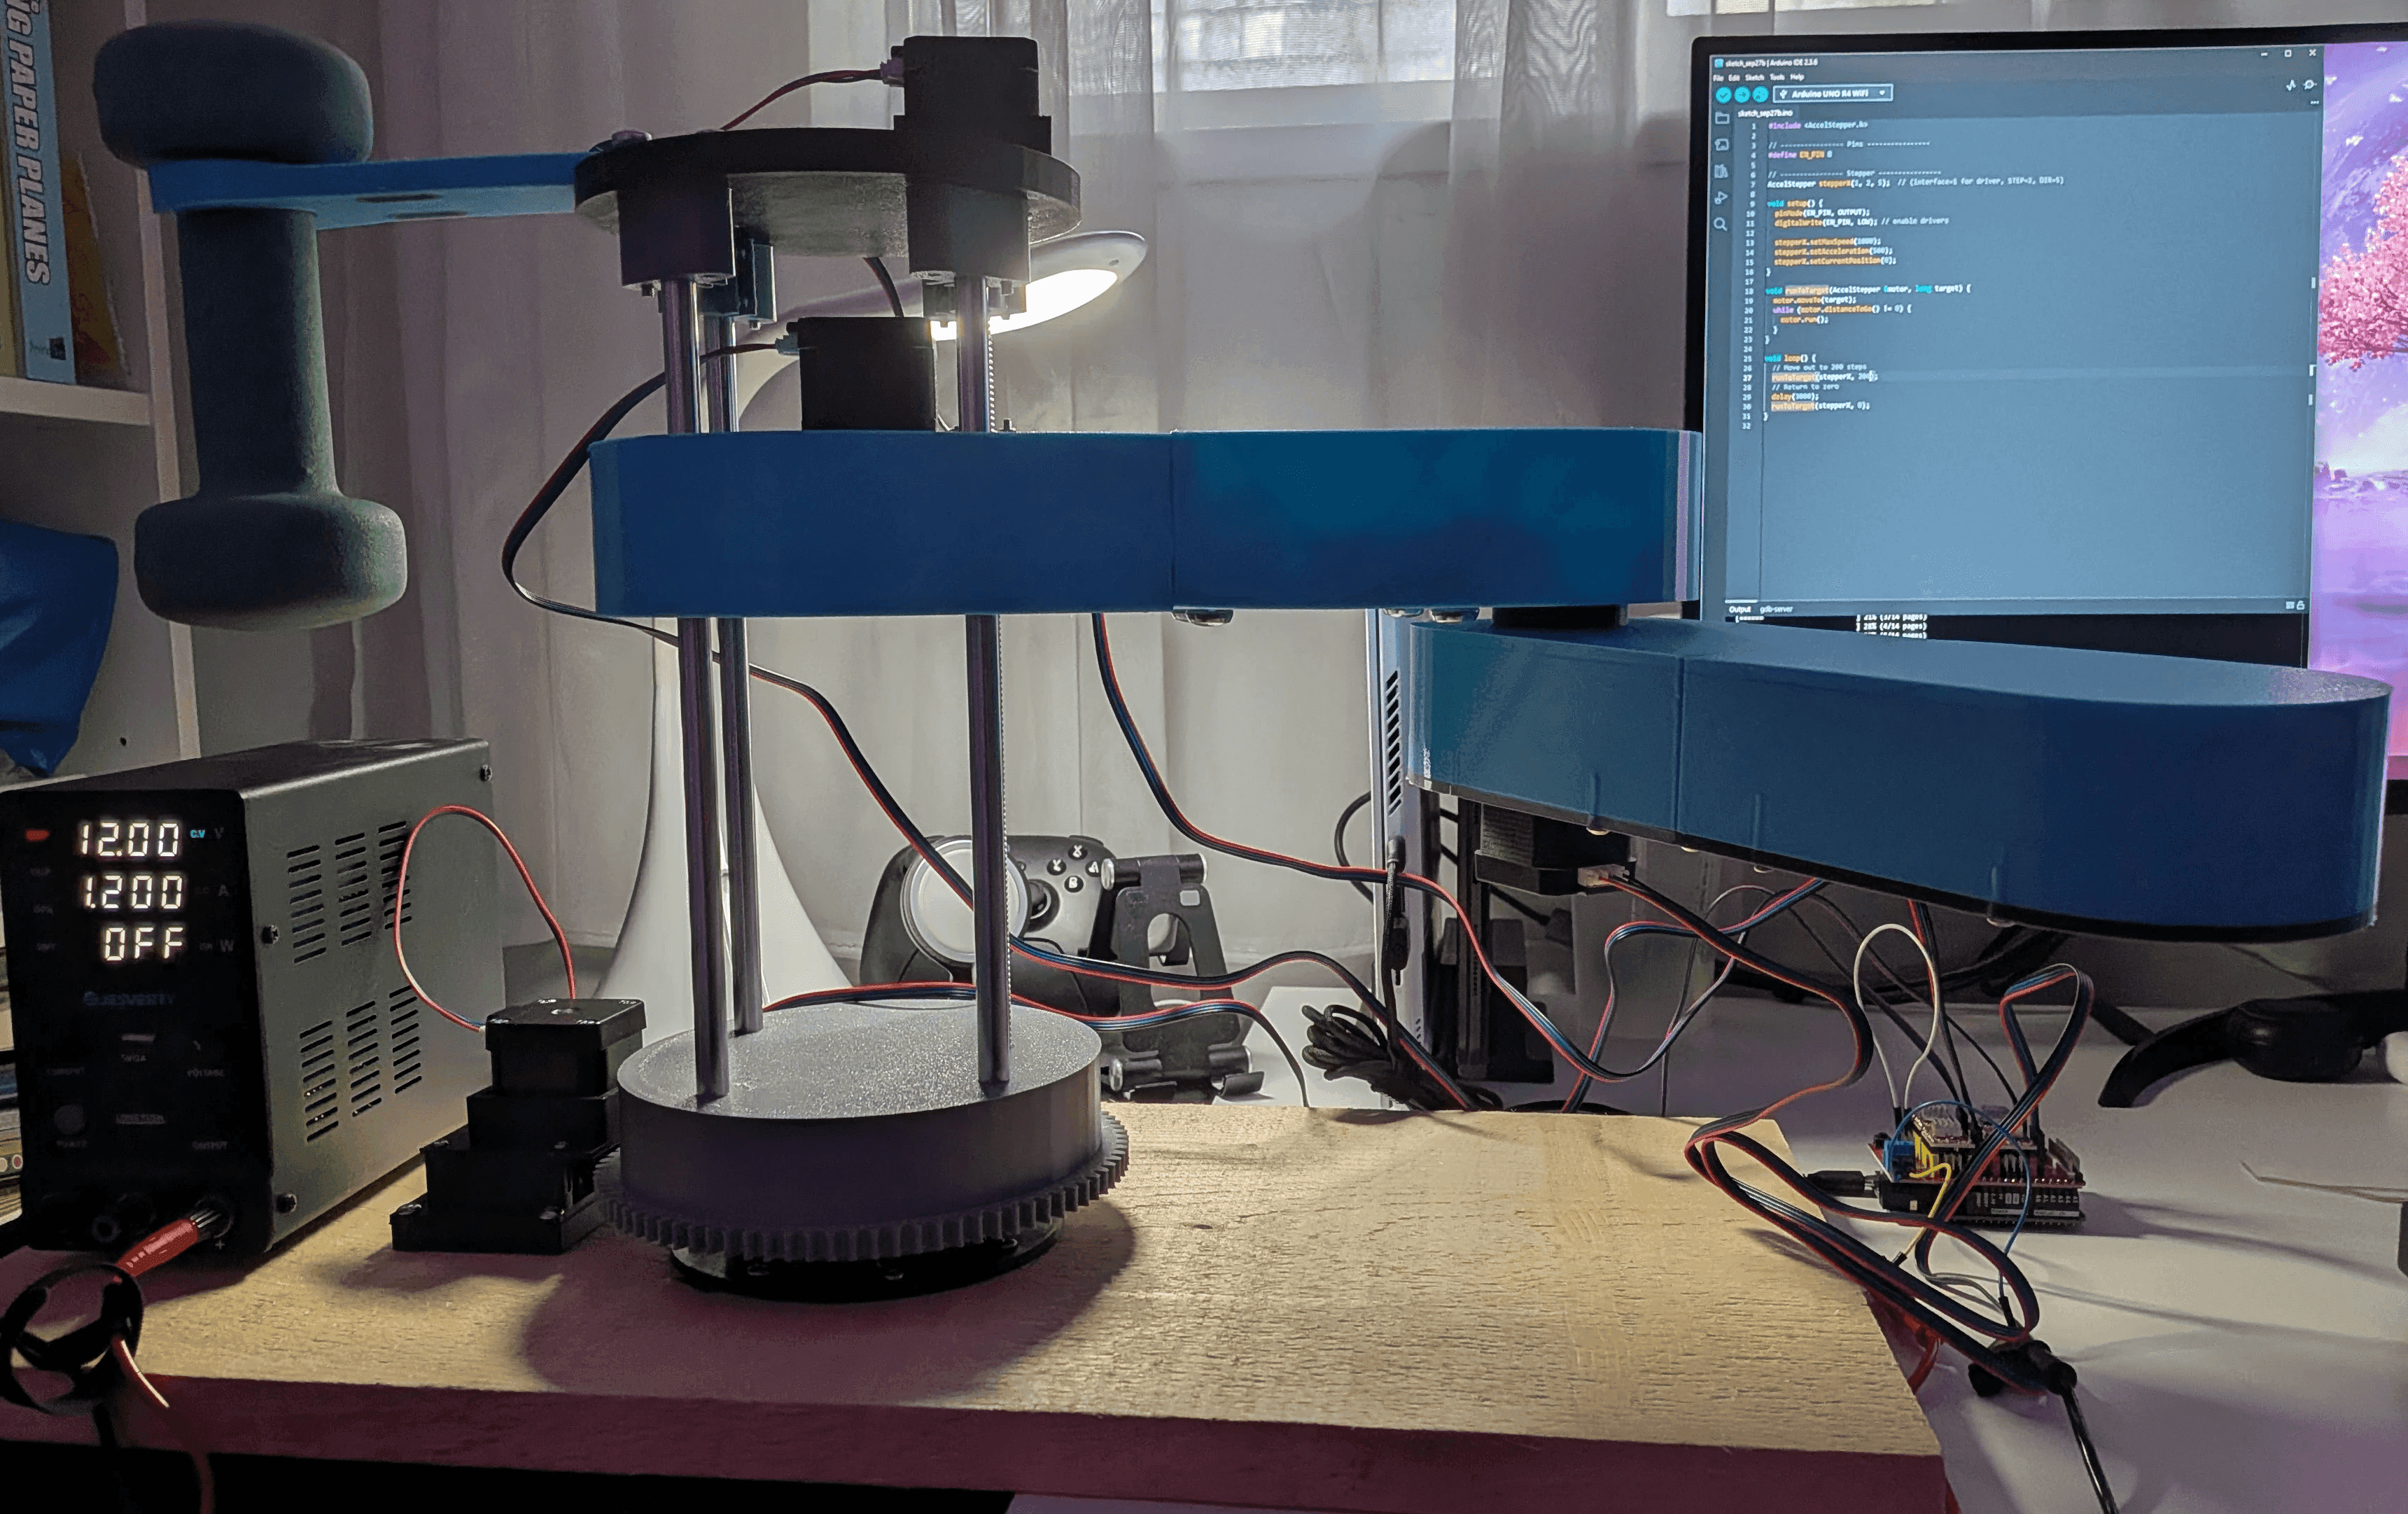
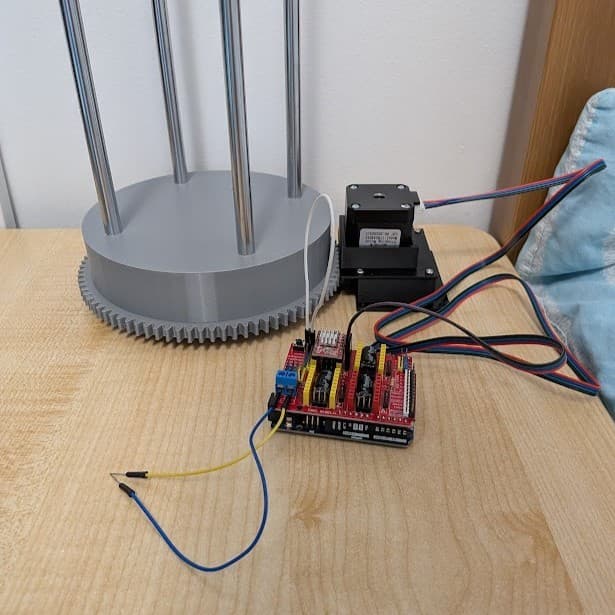
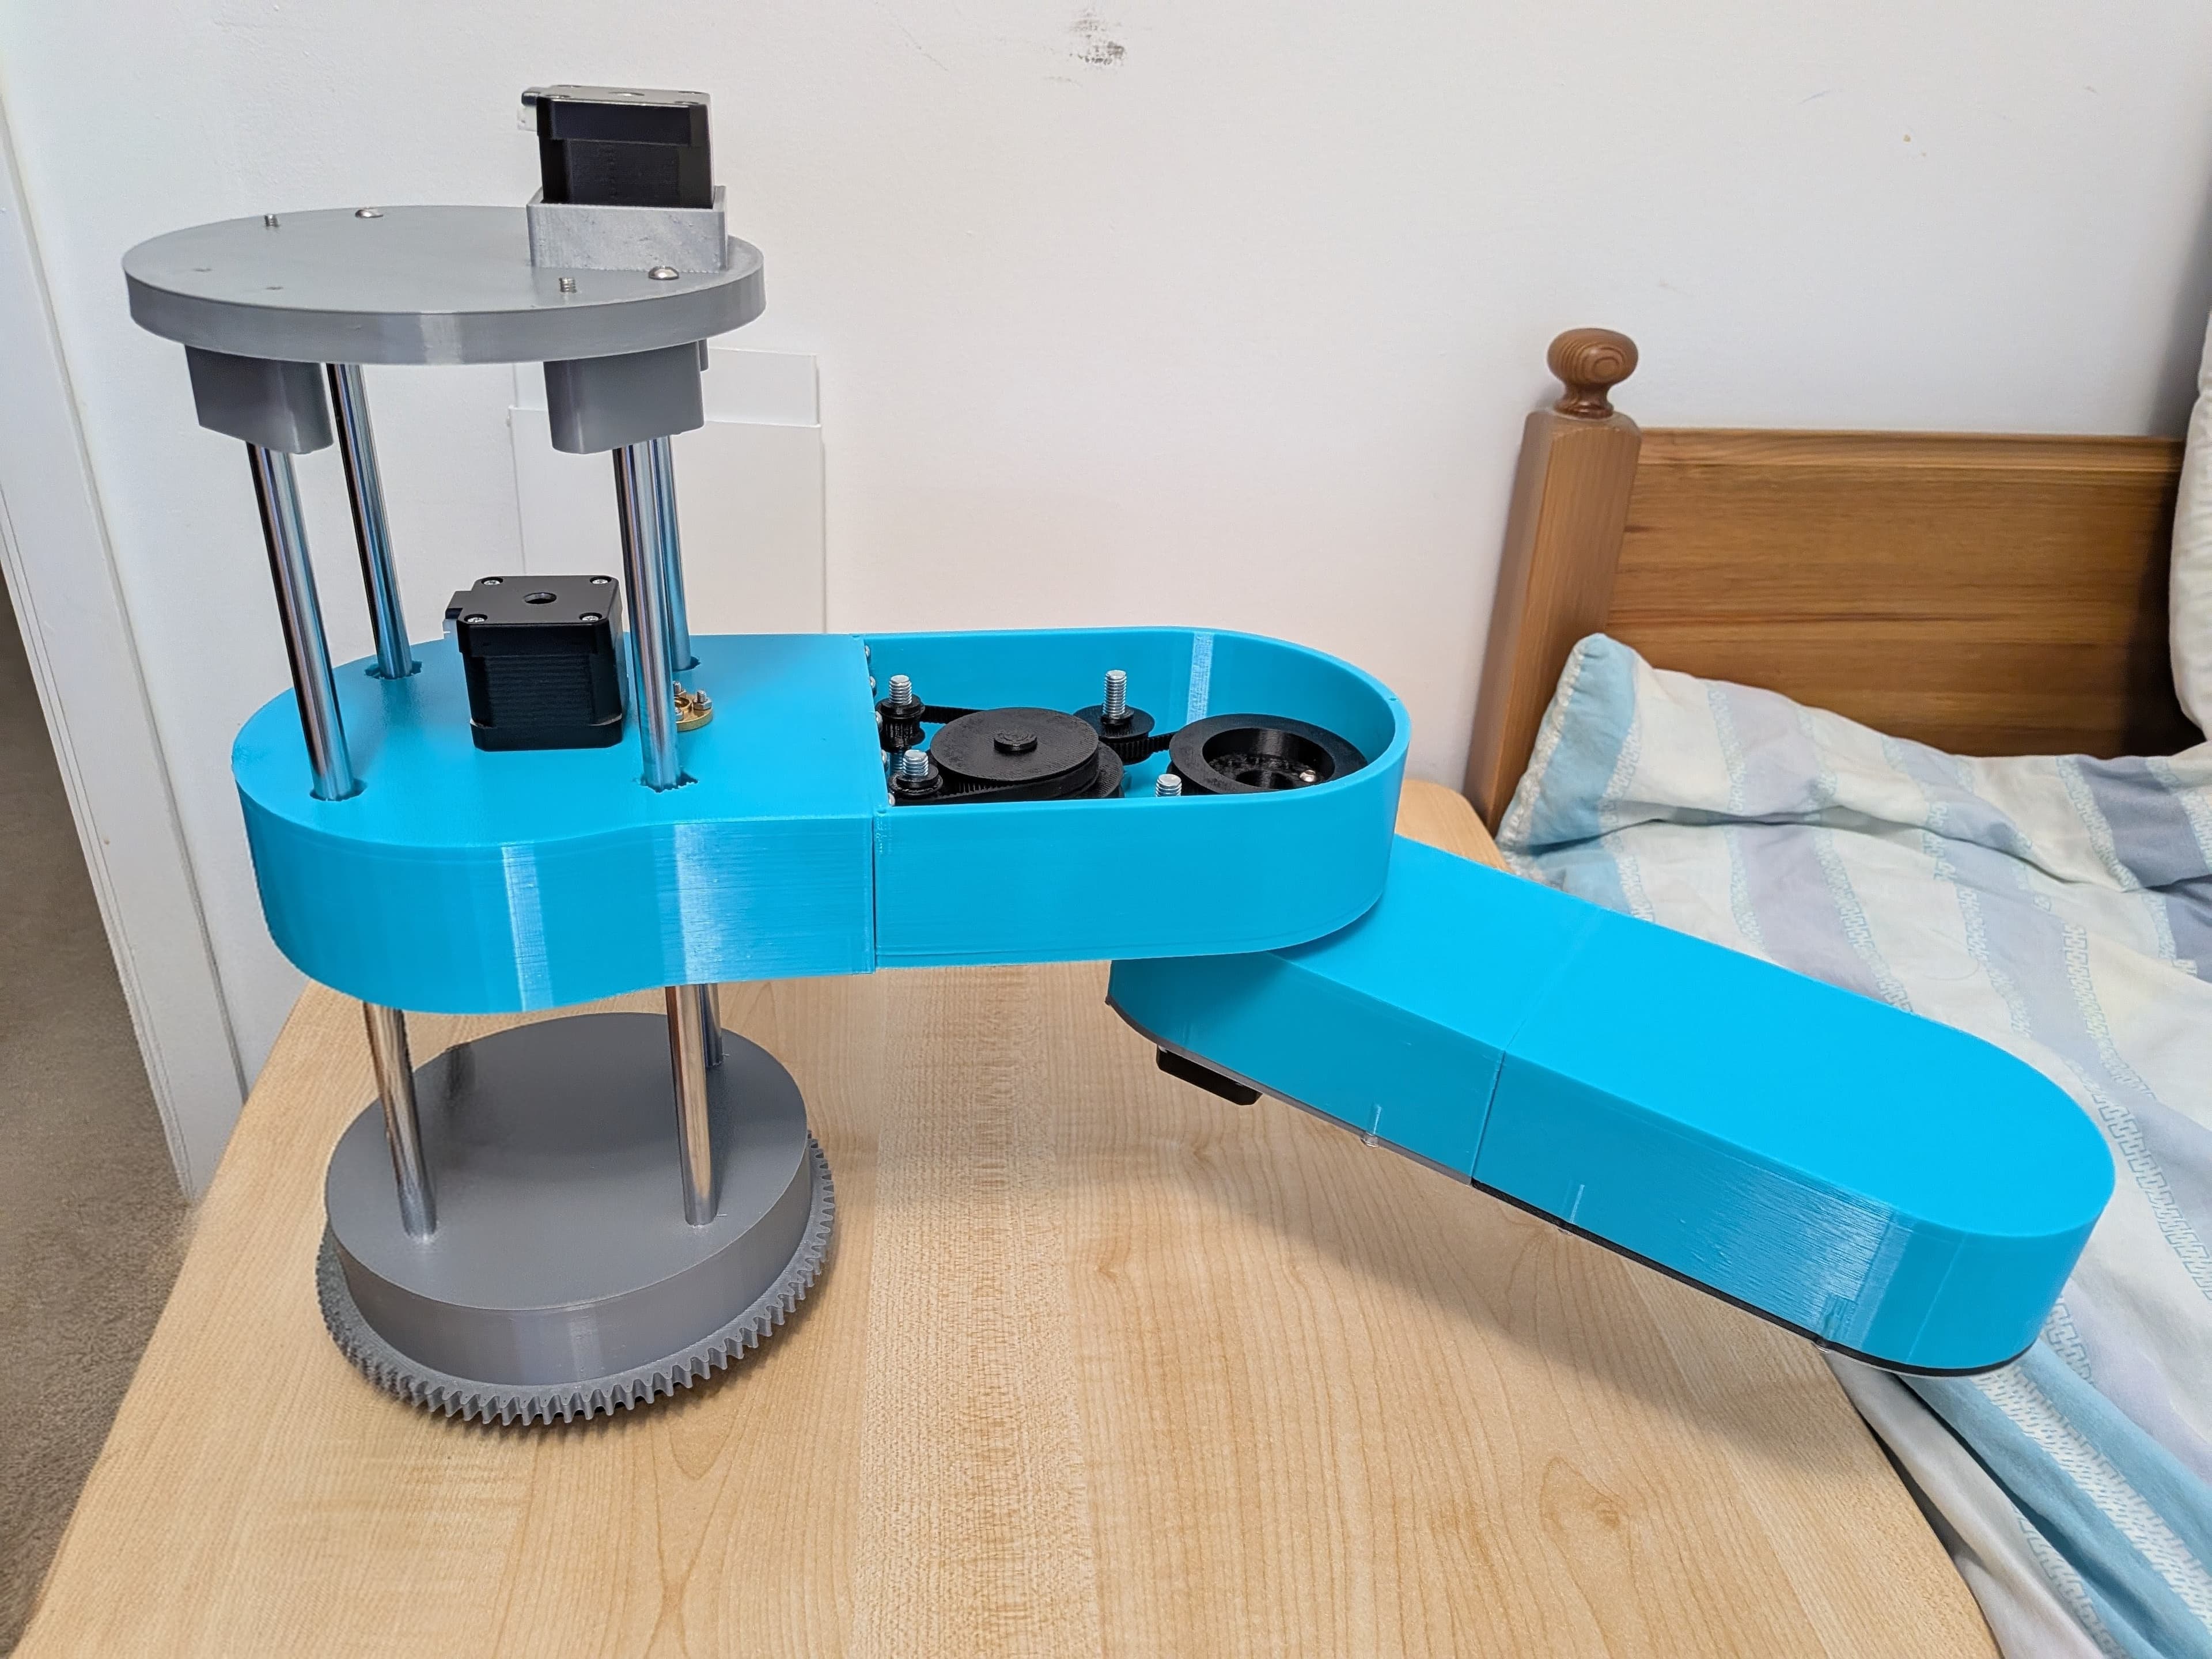
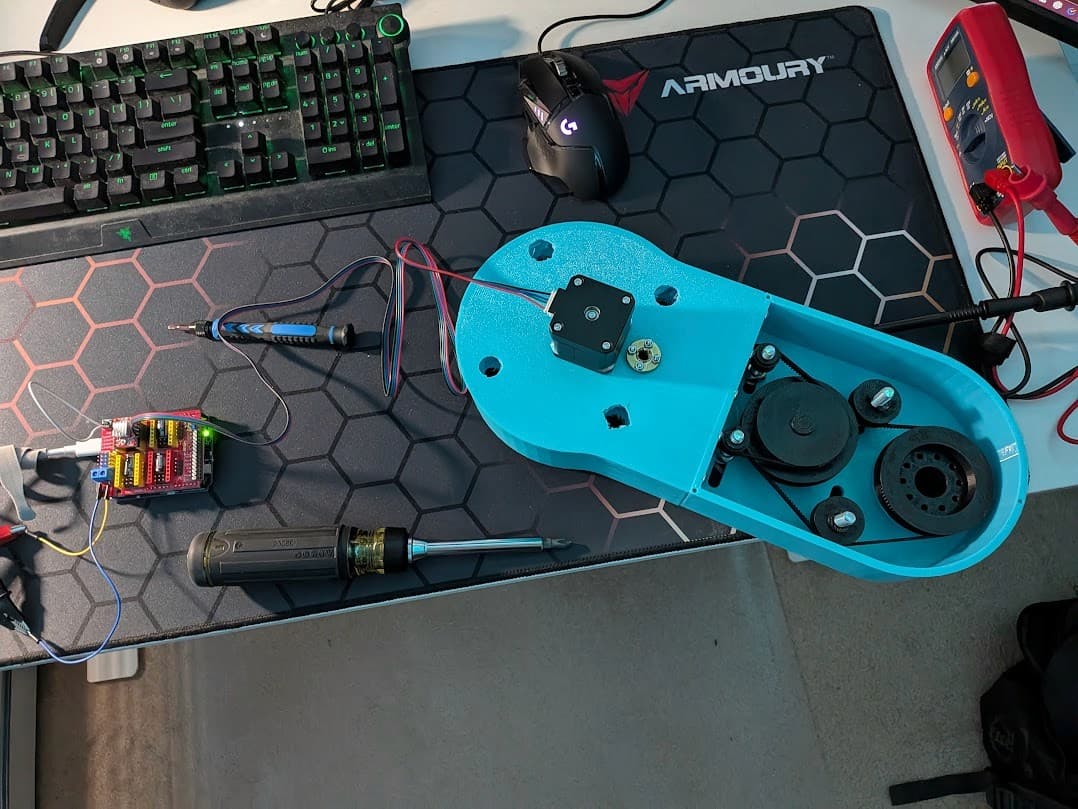
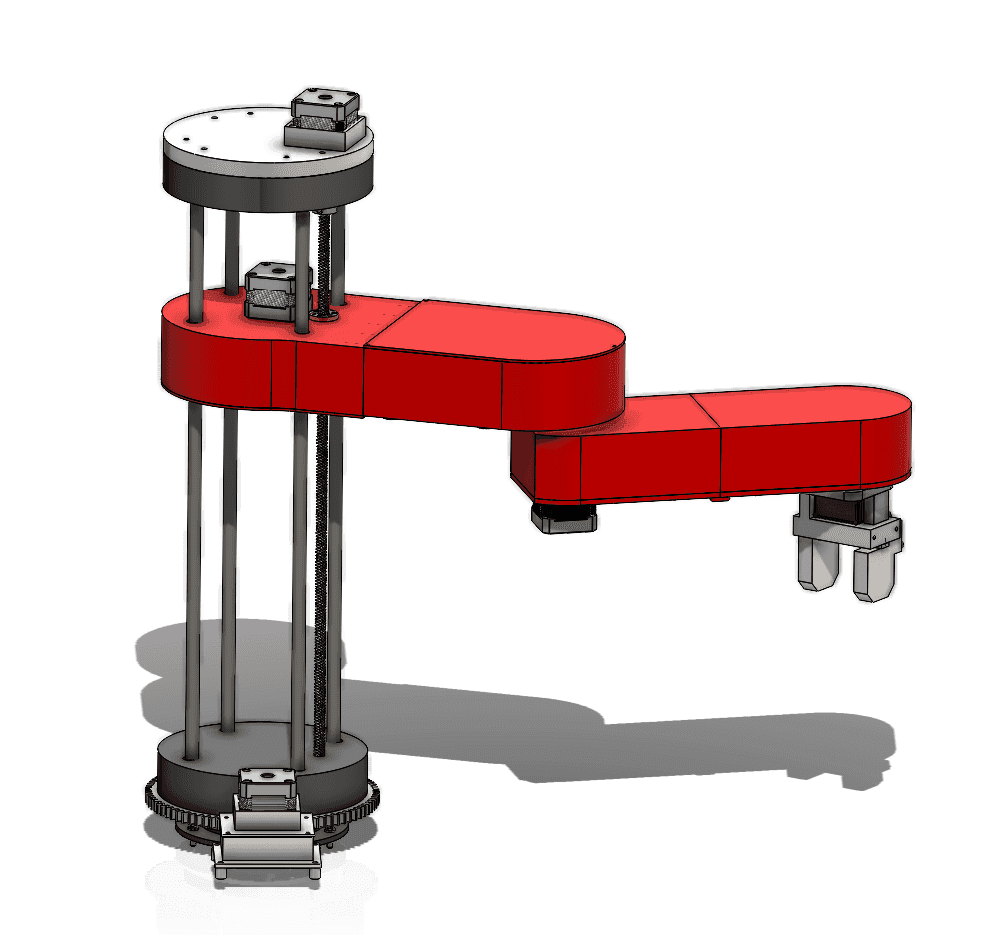
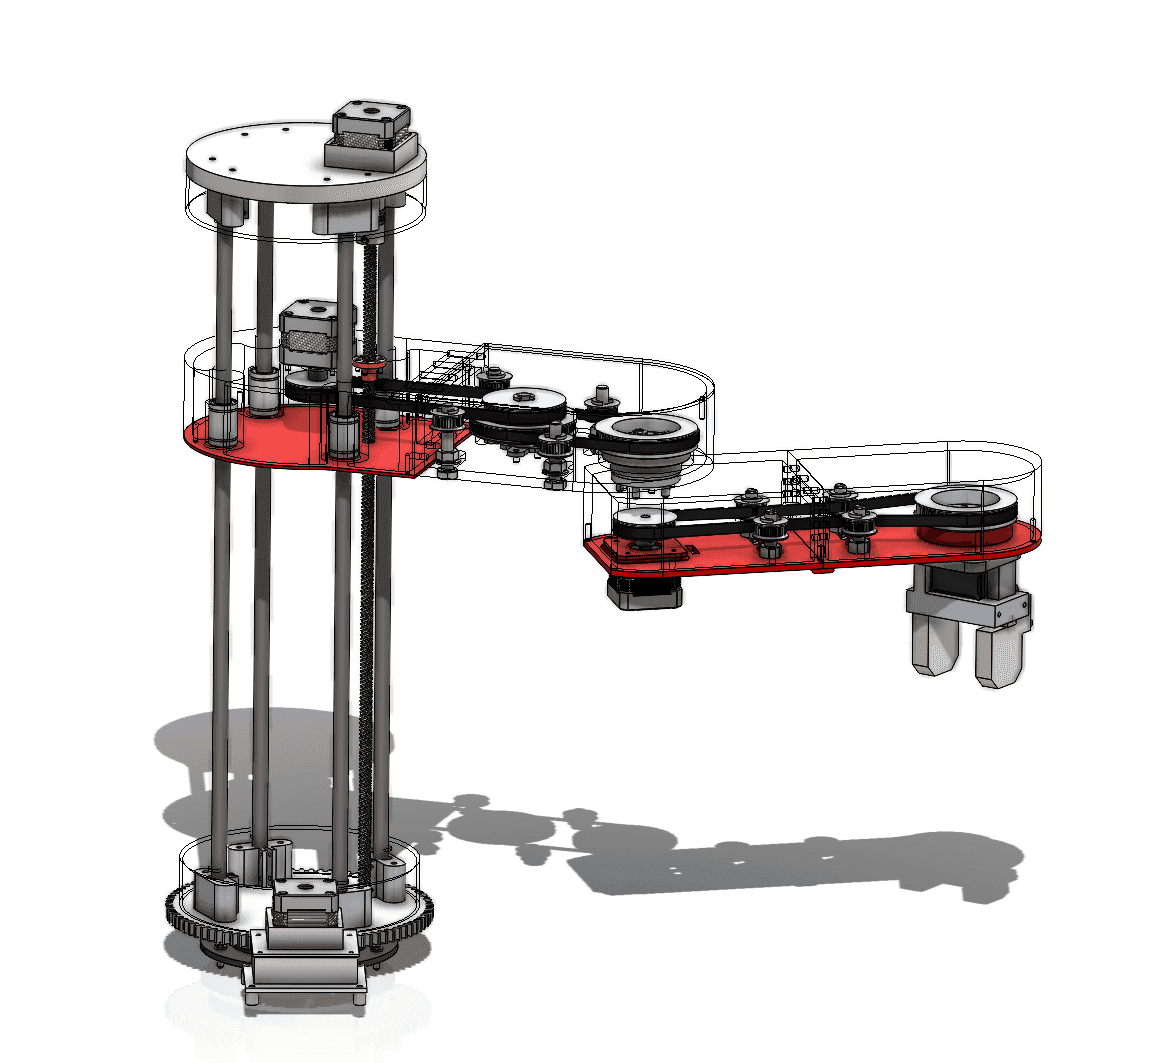
The system includes a geared stepper base, two equal-length linked arms for planar reach (one belt-driven), a lead-screw Z-axis, and a mount for a future servo gripper. All parts were designed in SolidWorks and 3D printed.
Motion currently runs through hard-coded sequences controlling base rotation, vertical lift, and forearm extension. A counterweight improves stability. Next iterations add a functional gripper and inverse-kinematics control.
Videos
Gallery