SFU FAS Competition 2026: Jellyfish Umbrella
Jellyfish-inspired kinetic umbrella with 8 articulated tentacles driven by dual-servo cable actuation, ESP32 control, and modular 3D-printed segments.
- SolidWorks
- ESP32
- Servo actuation
- 3D printing
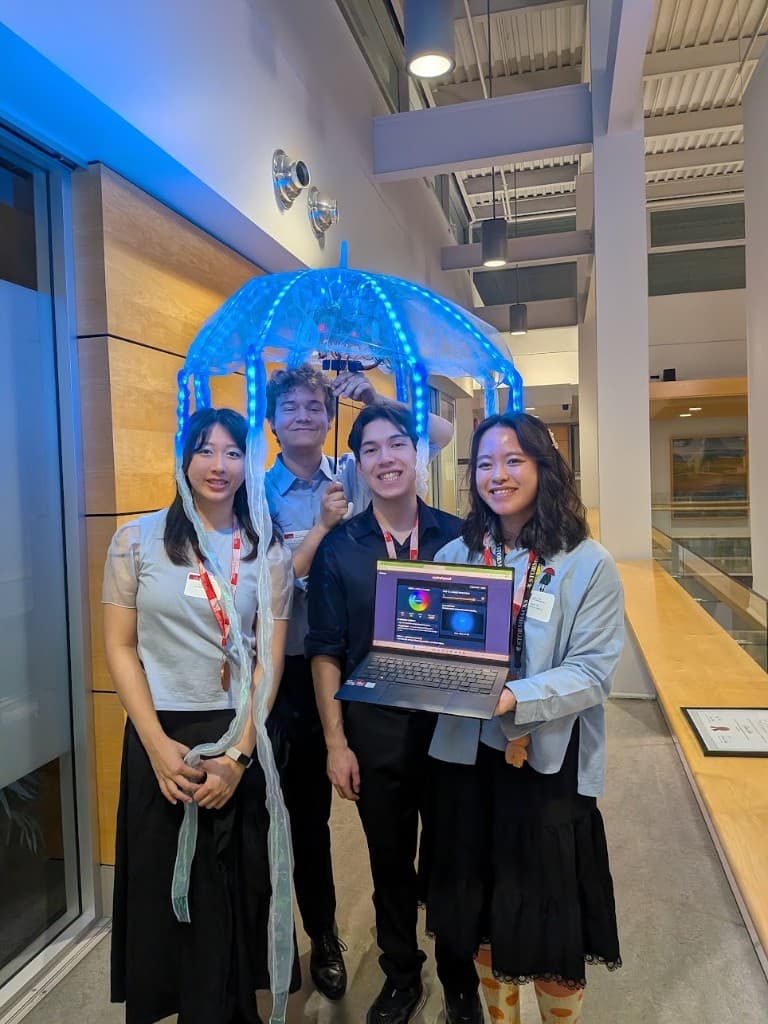
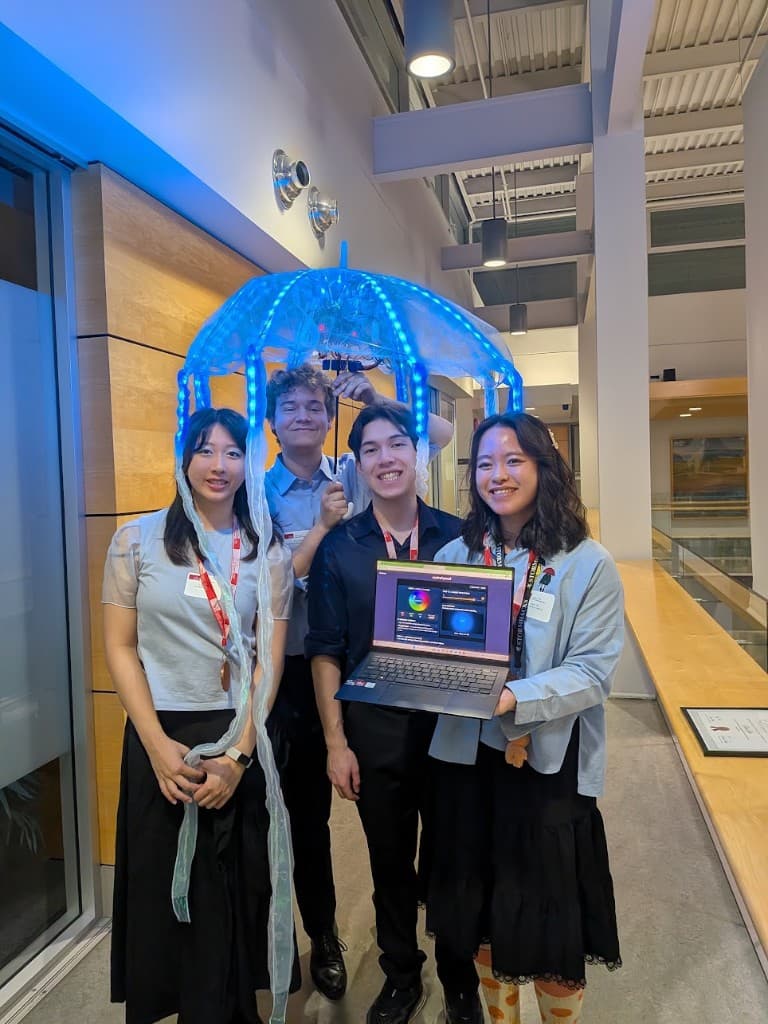
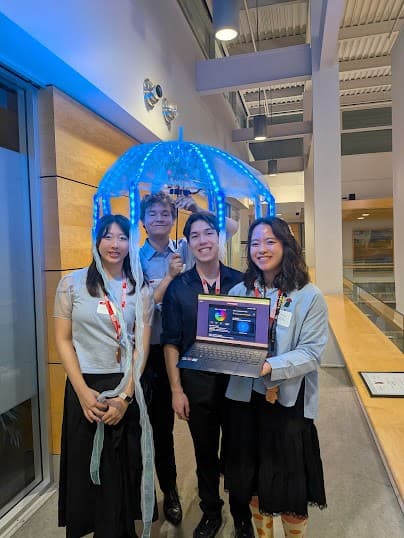
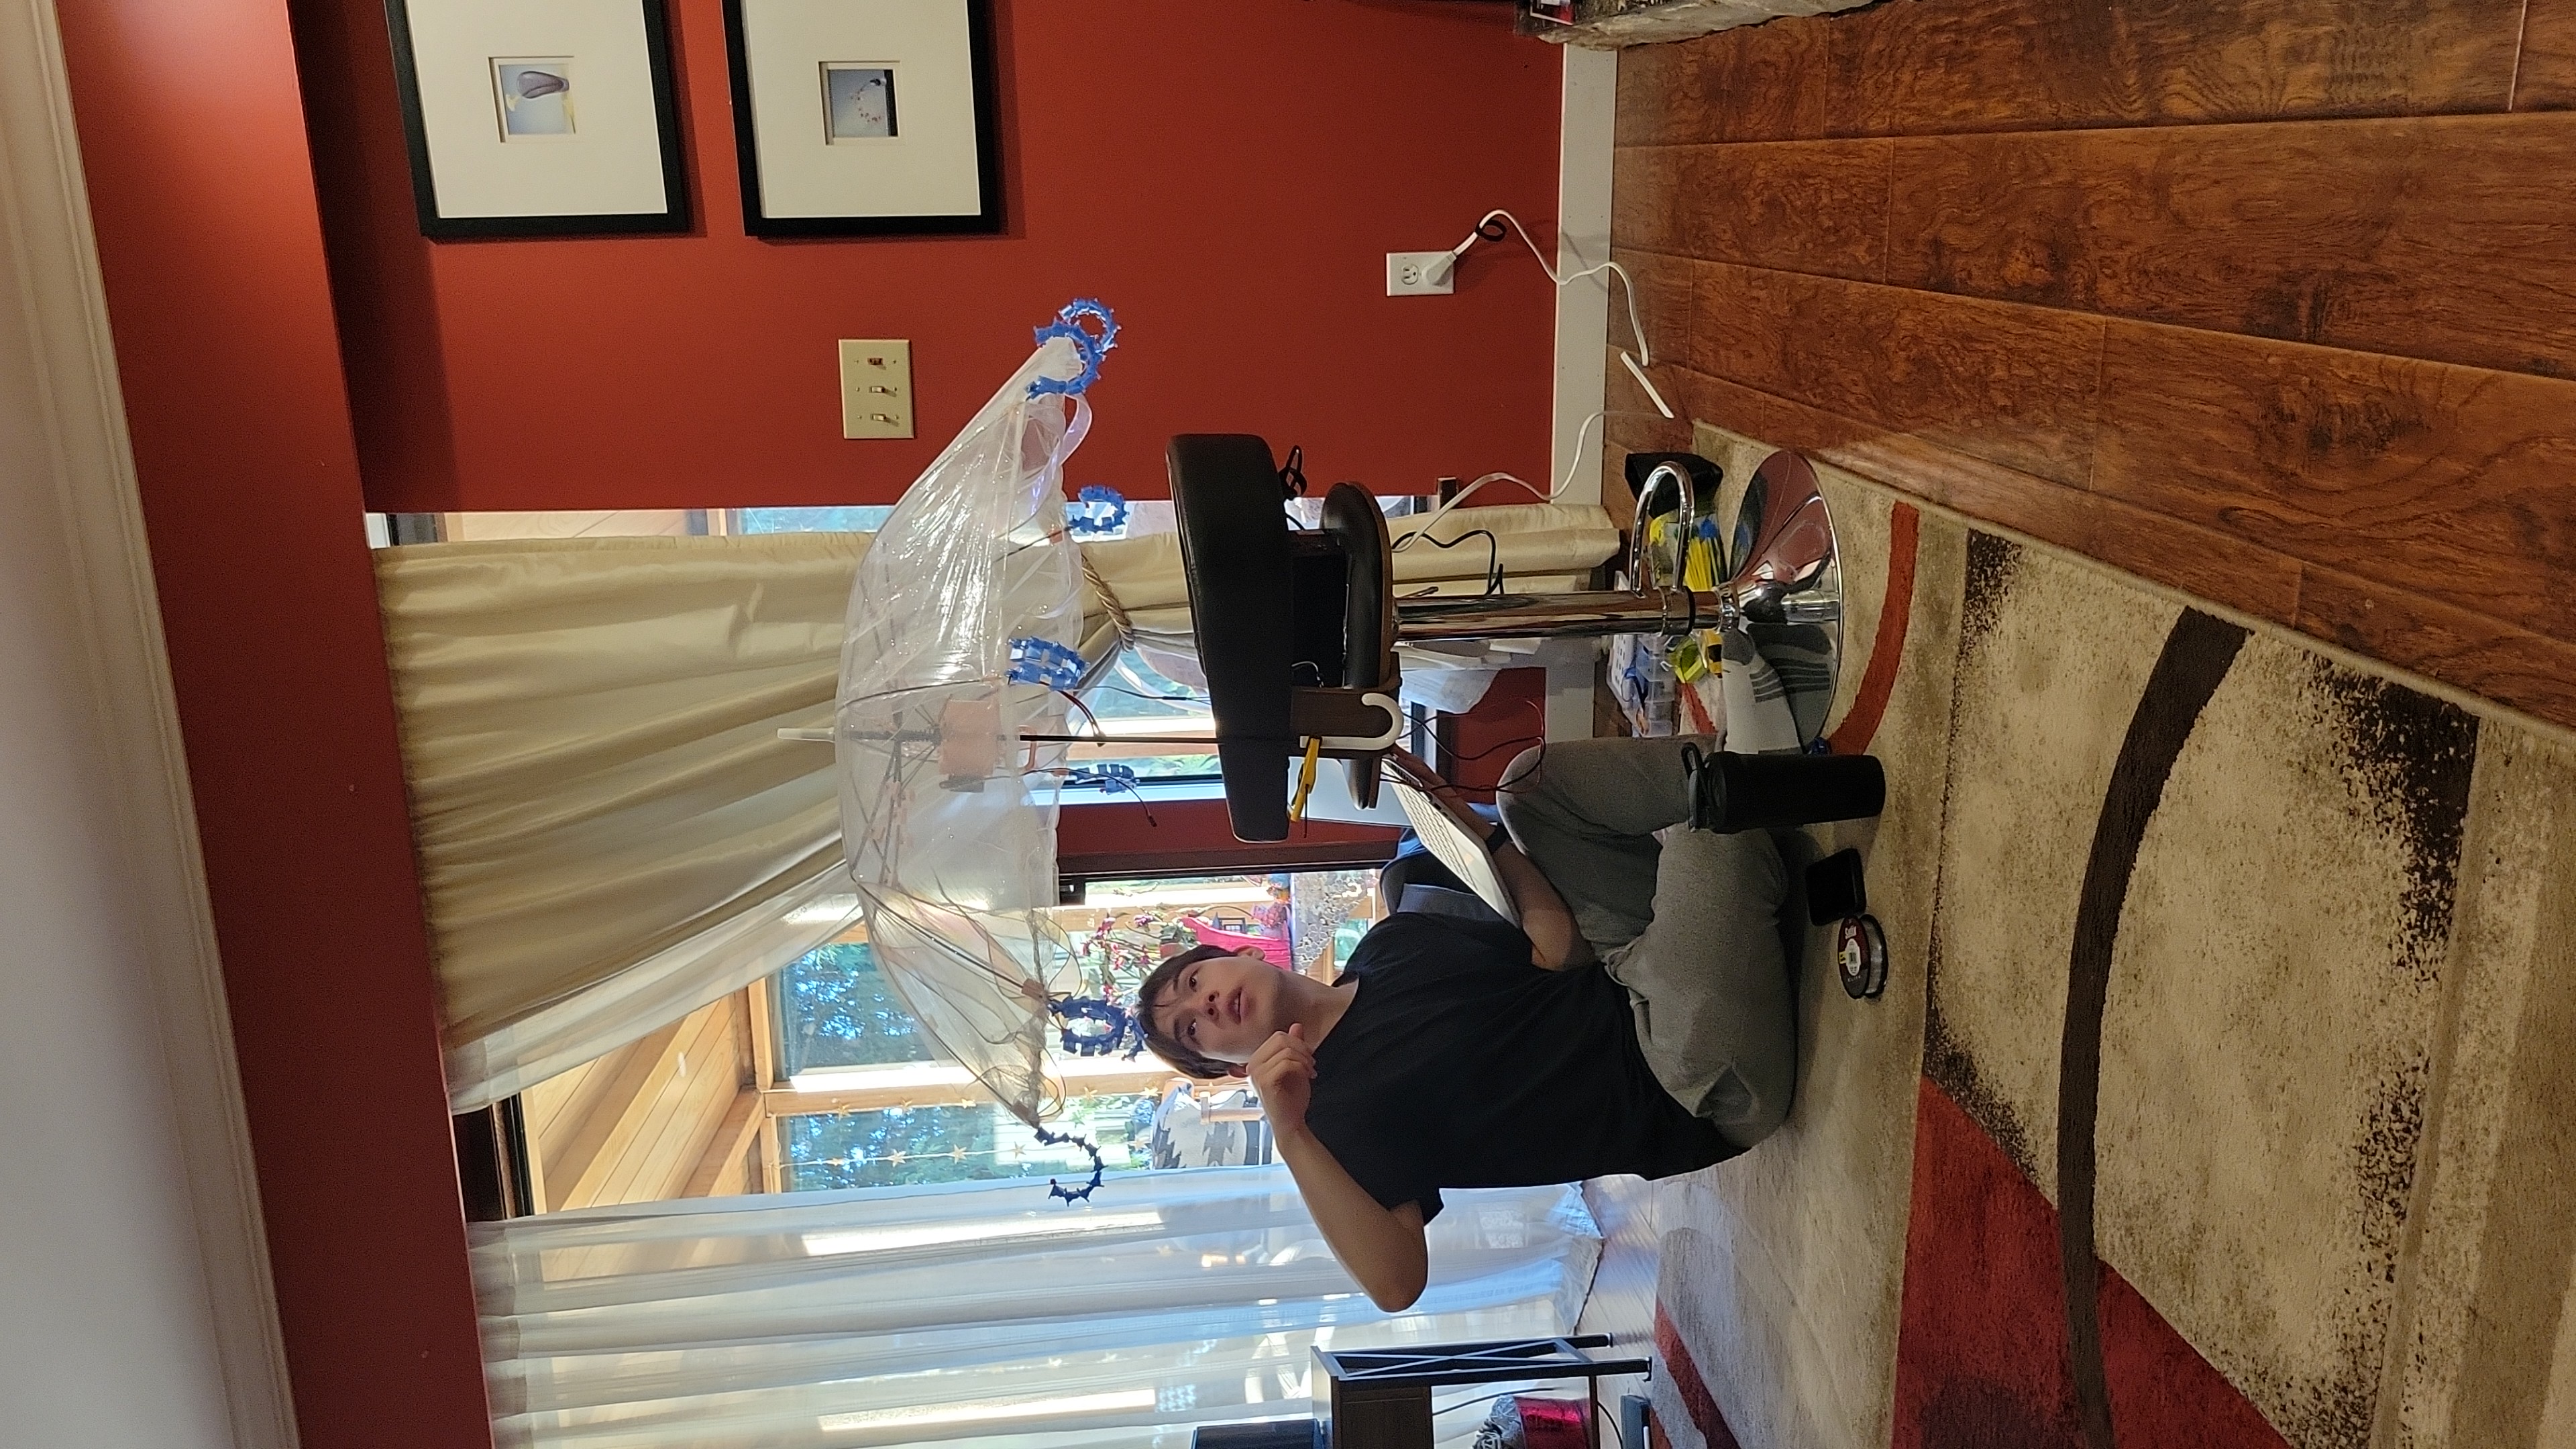
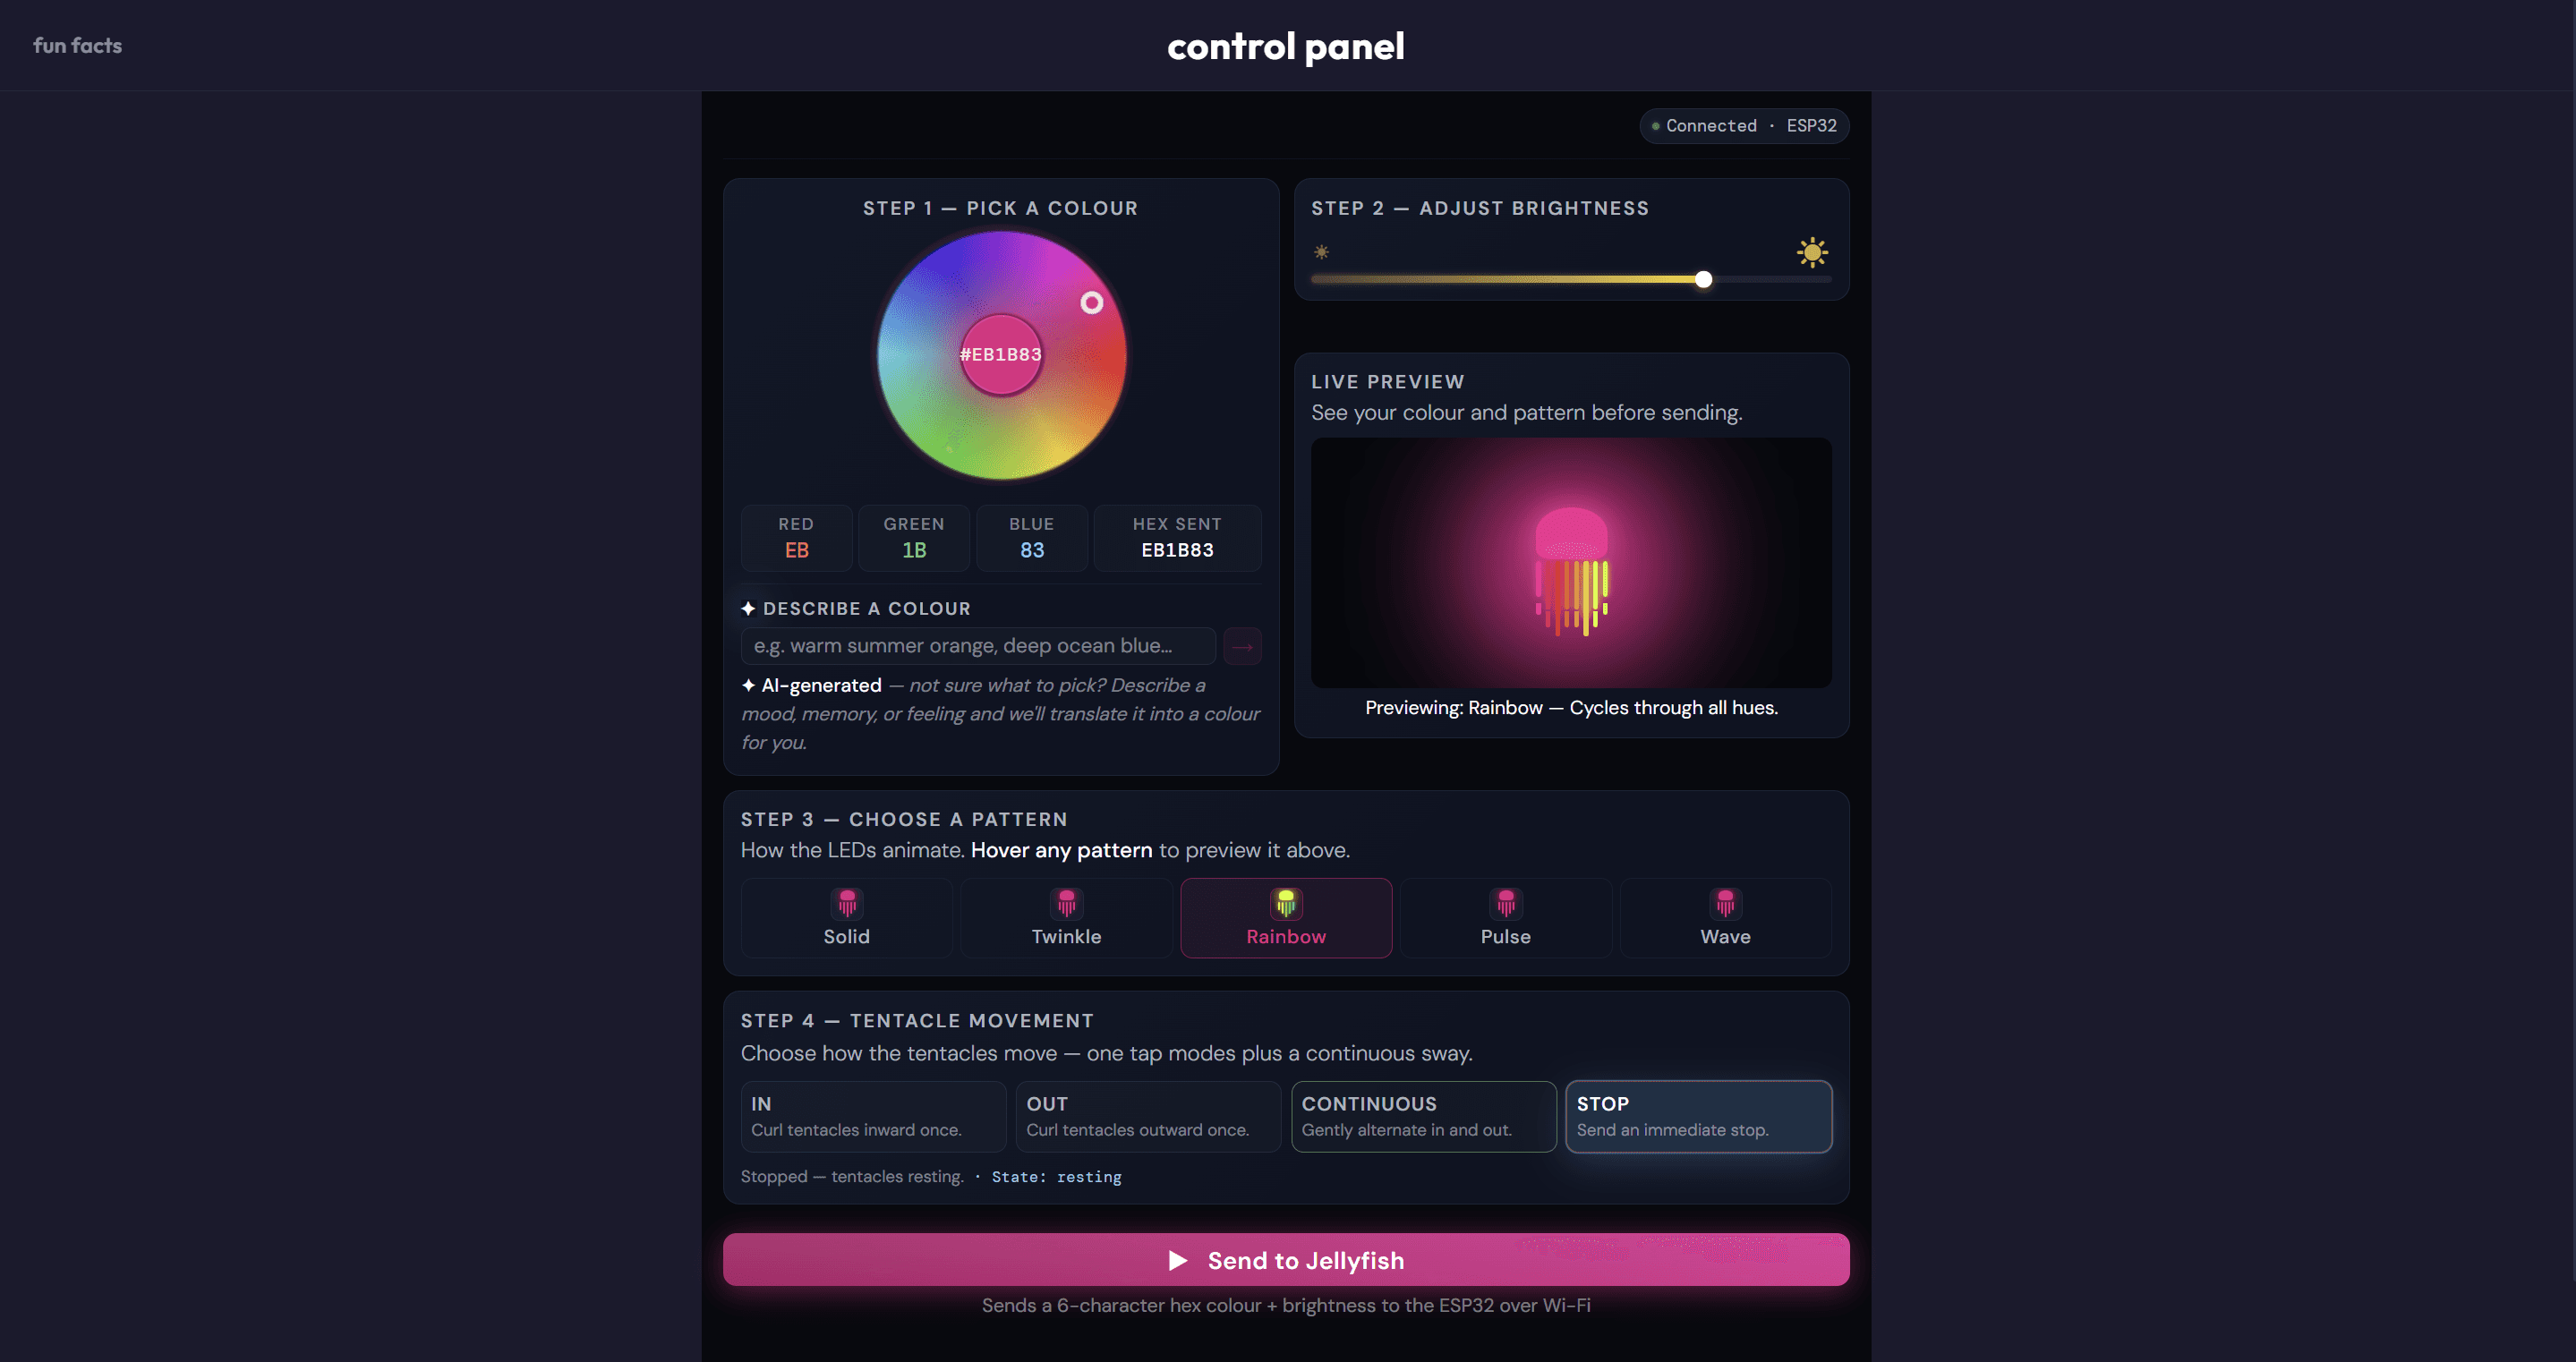
SFU’s annual Faculty of Applied Sciences (FAS) Competition was held in March 2026. The prompt was to create a project that would inspire K-12 students to pursue applied sciences. Our four-person team built a Jellyfish Umbrella: converting a standard umbrella into one that visually and mechanically resembles a jellyfish.
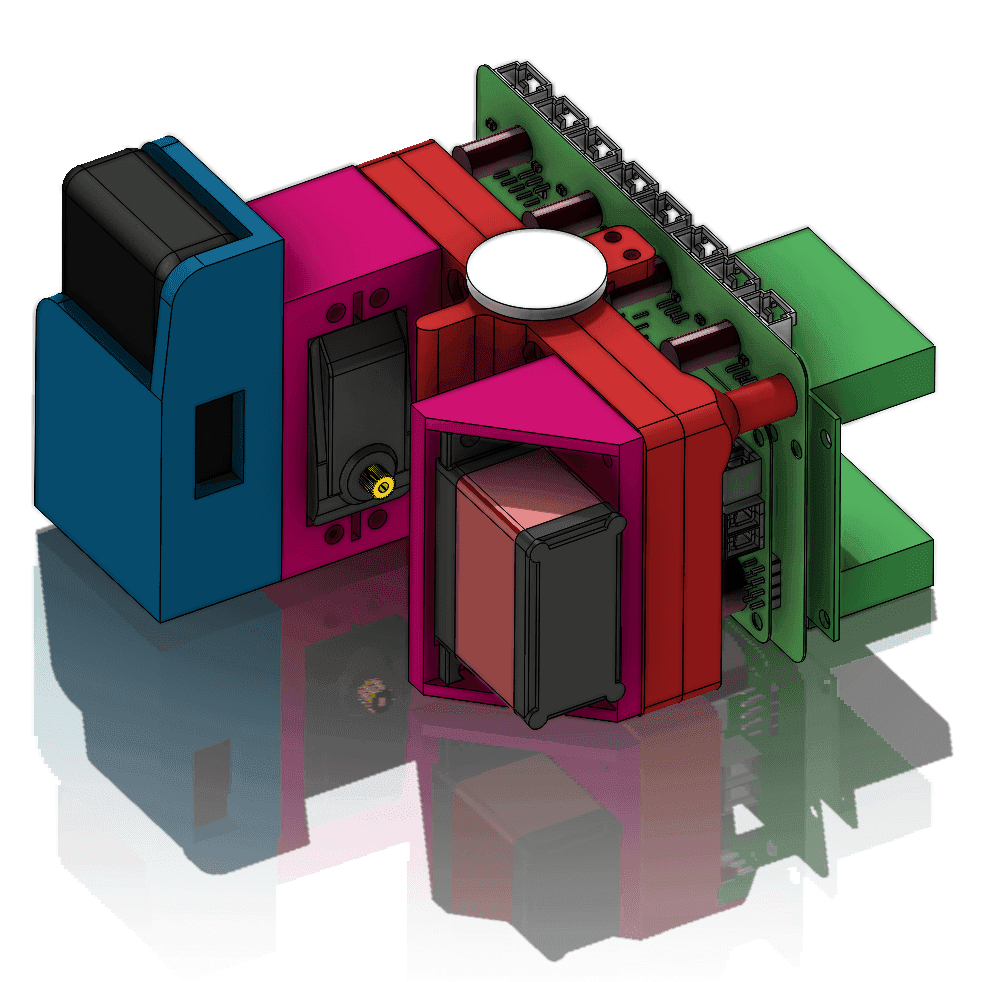
My role focused on mechanical engineering design: electronics housing, tentacle actuation, and the segmented tentacle structure. I also kept the umbrella able to fold and open normally. Teammates handled the control web app, visual design, and electronics integration.
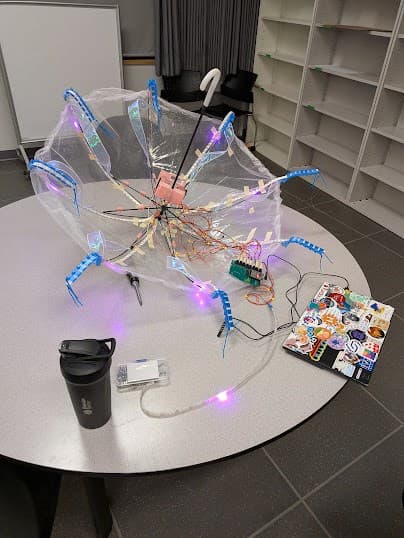
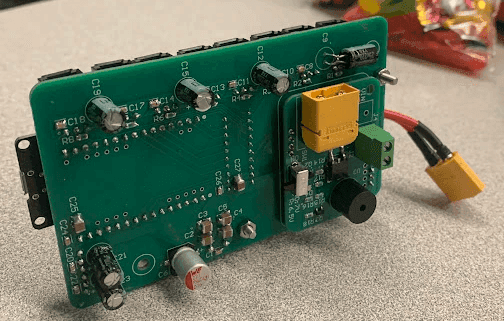
Primary electronics mounted on the moving umbrella shaft kept the system compact. Two high-torque servos (20 kg·cm) actuated eight tentacles via fishing-line cable routing: one motor extending outward, the other retracting inward.
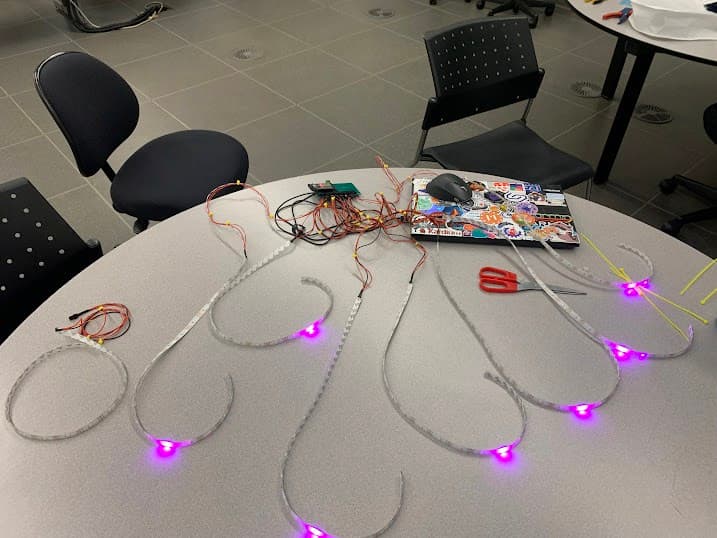
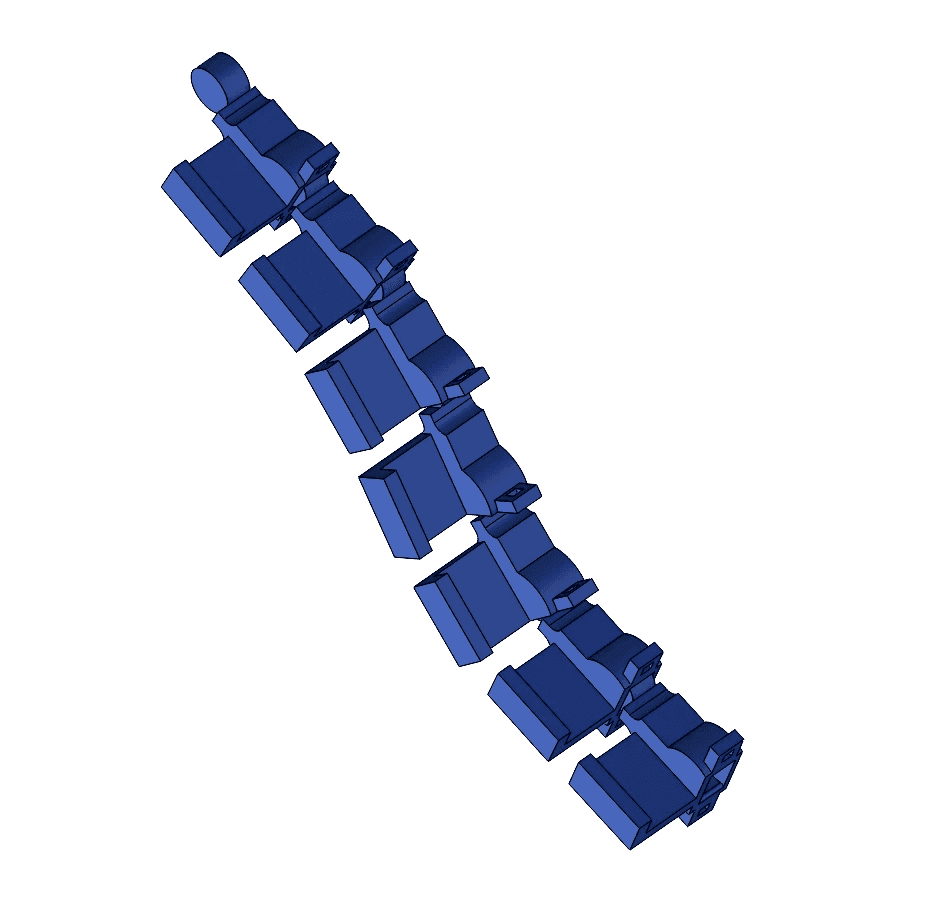
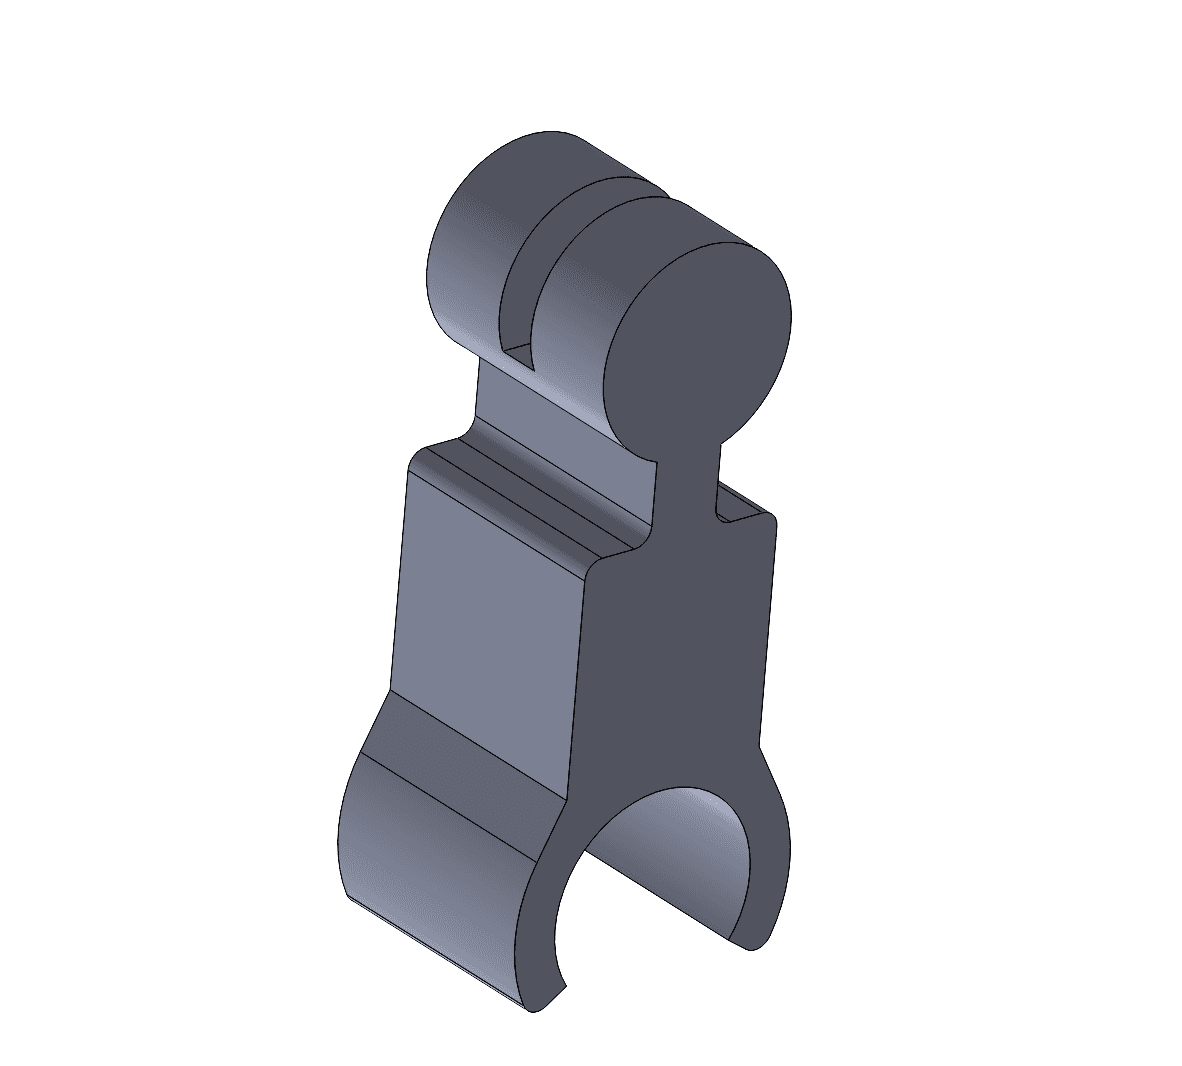
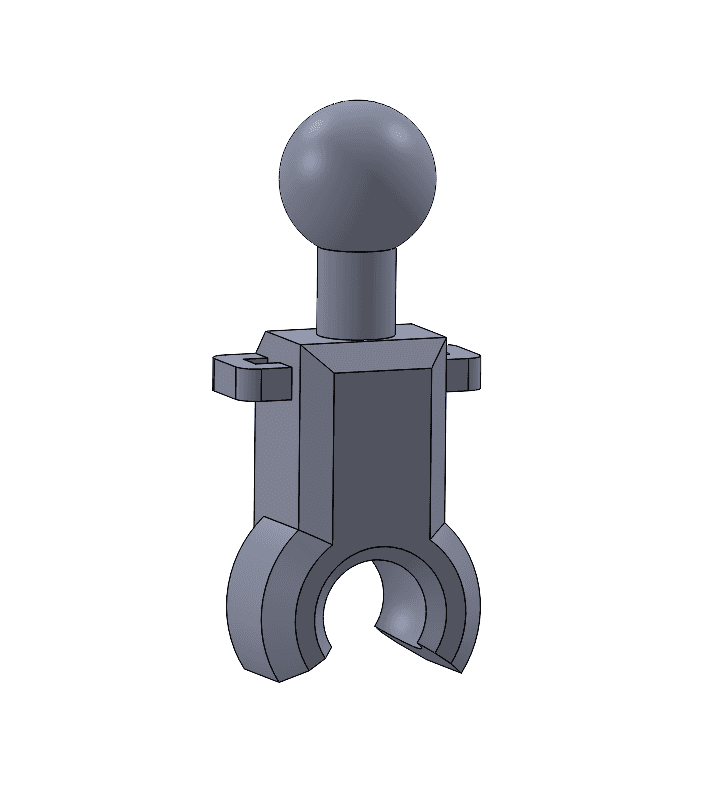
Tentacles went through several iterations. The final design uses modular pin-jointed links with cable-management channels for LED strips, snap-fit assembly, and tolerances tuned for Bambu Lab printers. The team spent over 350 hours across design, printing, electronics, and assembly.
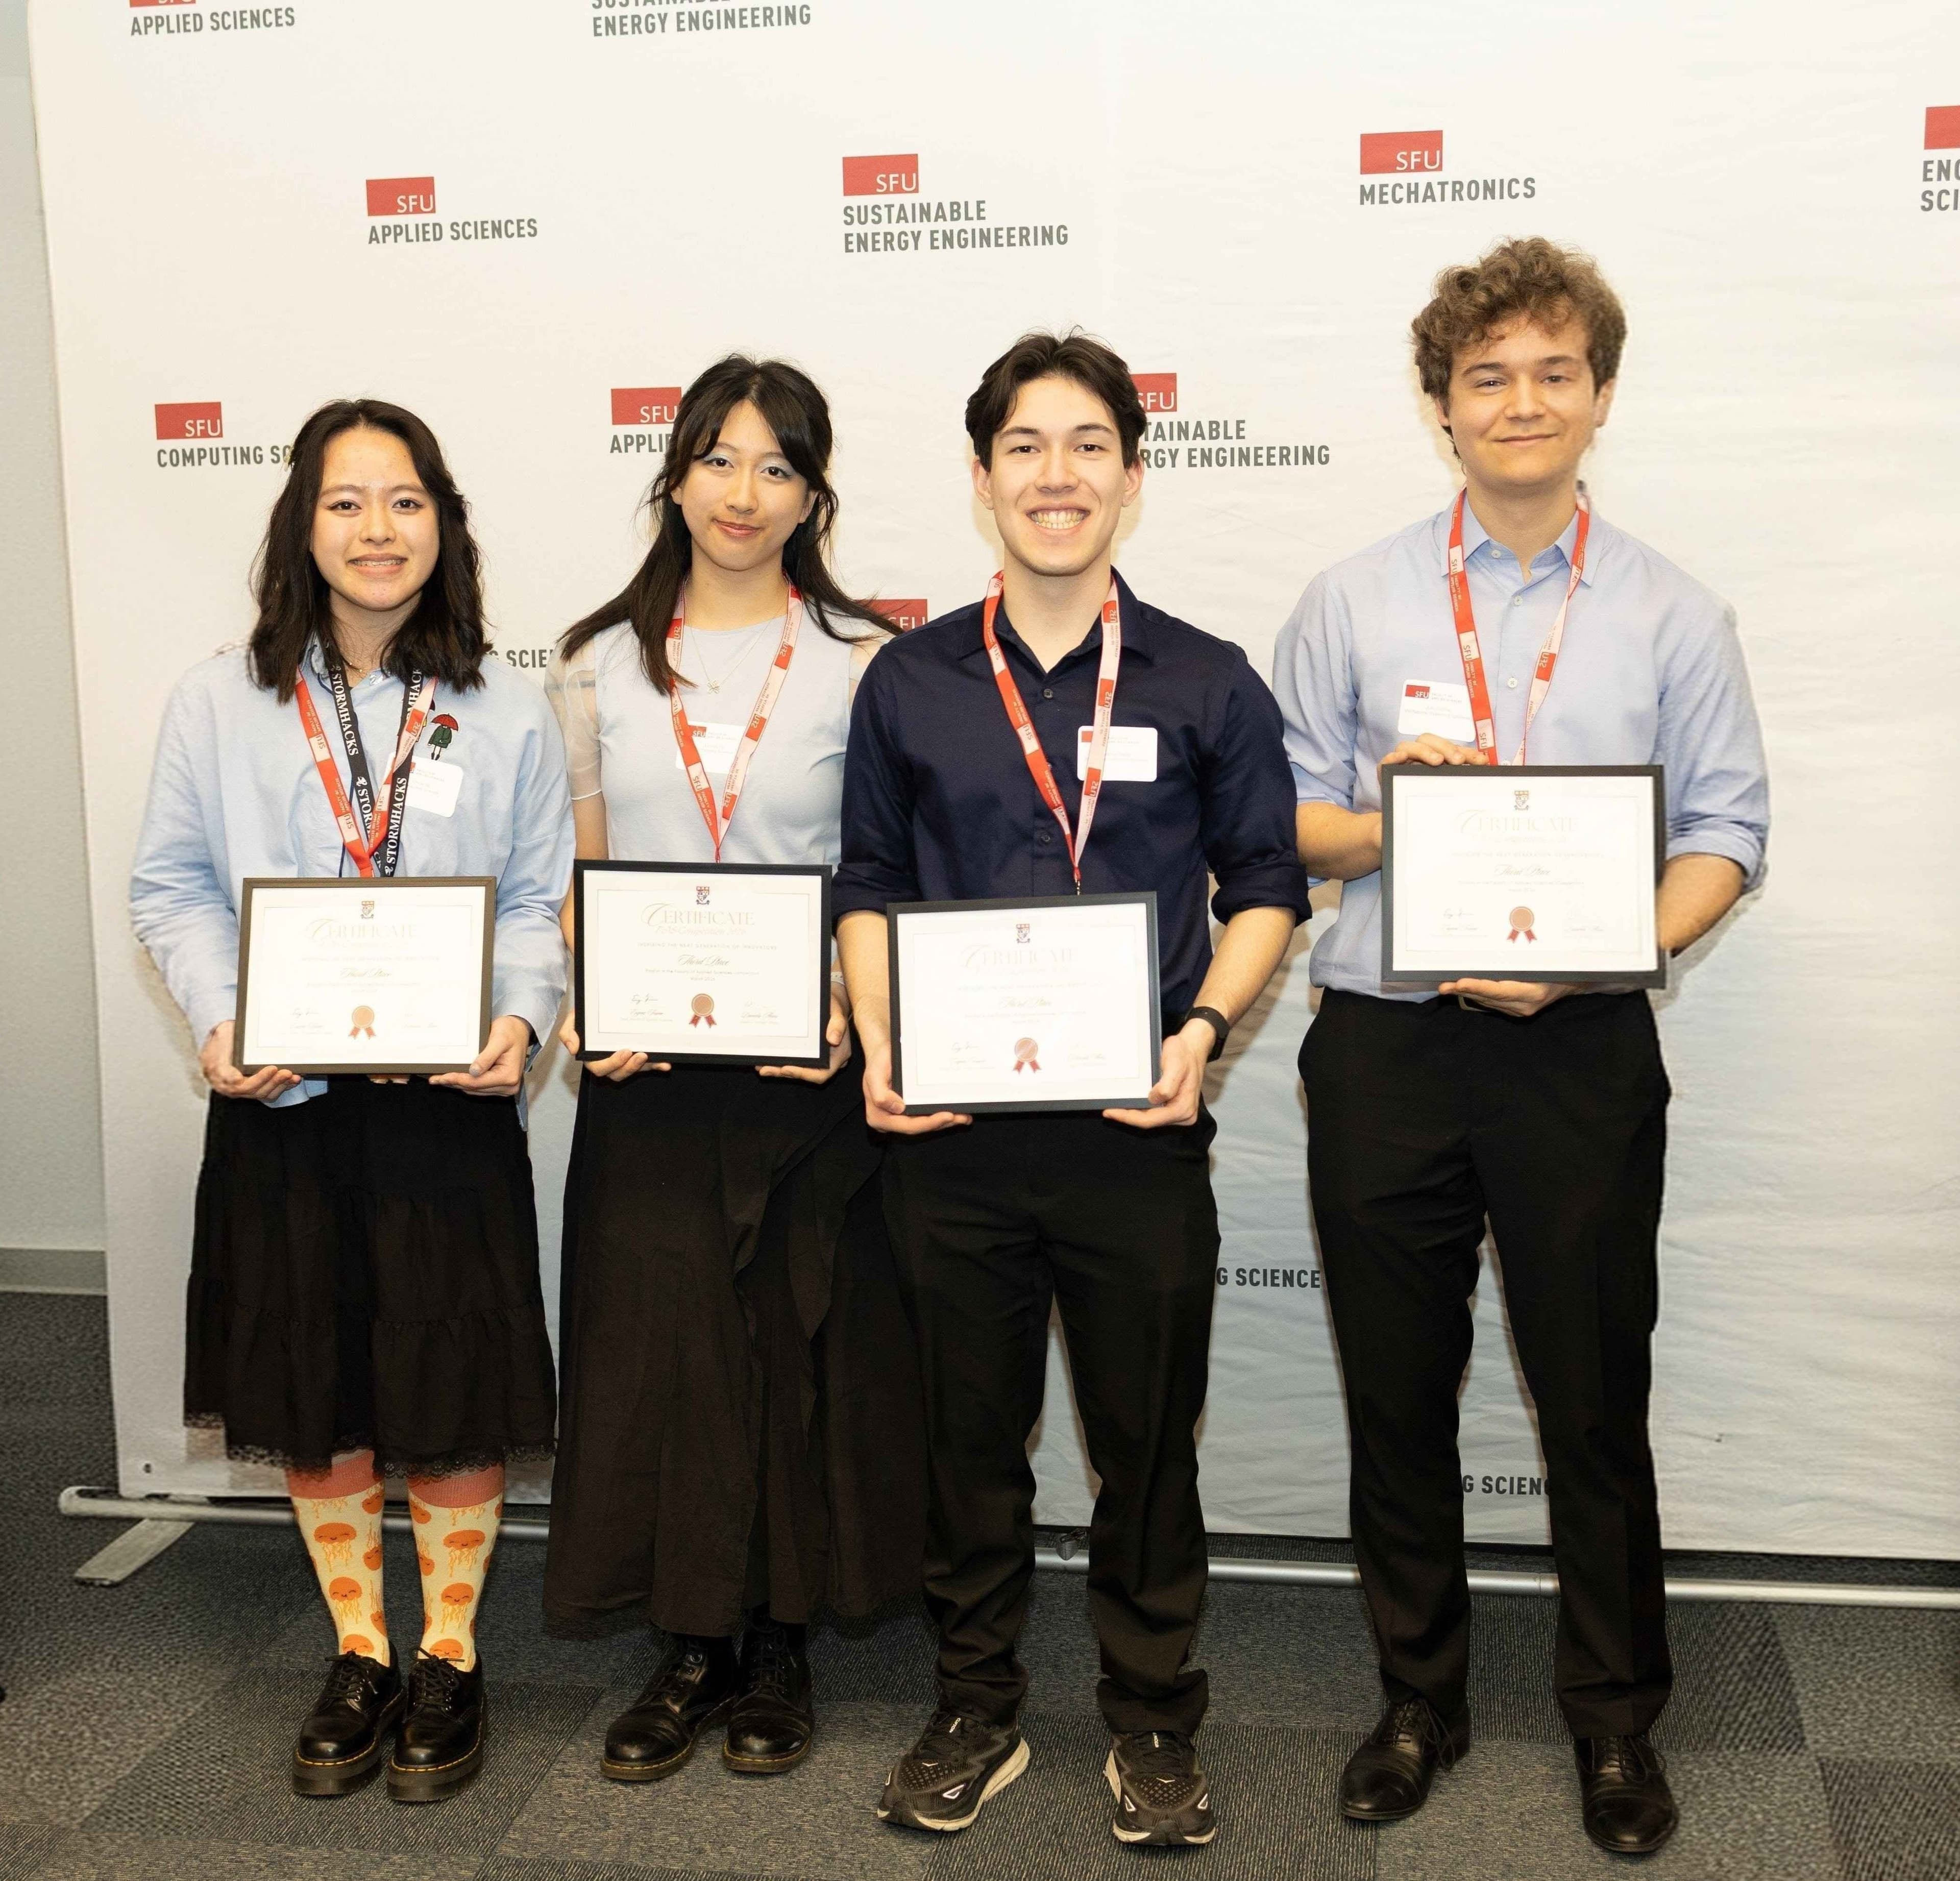
We placed 3rd. Prize money covered parts. This is the kind of build I like: pick a hard problem and iterate until it works.
Gallery